
1 / 5
ODM Custom CNC Machined Robot Finger Joint Link Manufacturer, Exporter
Product Description
Product Overview
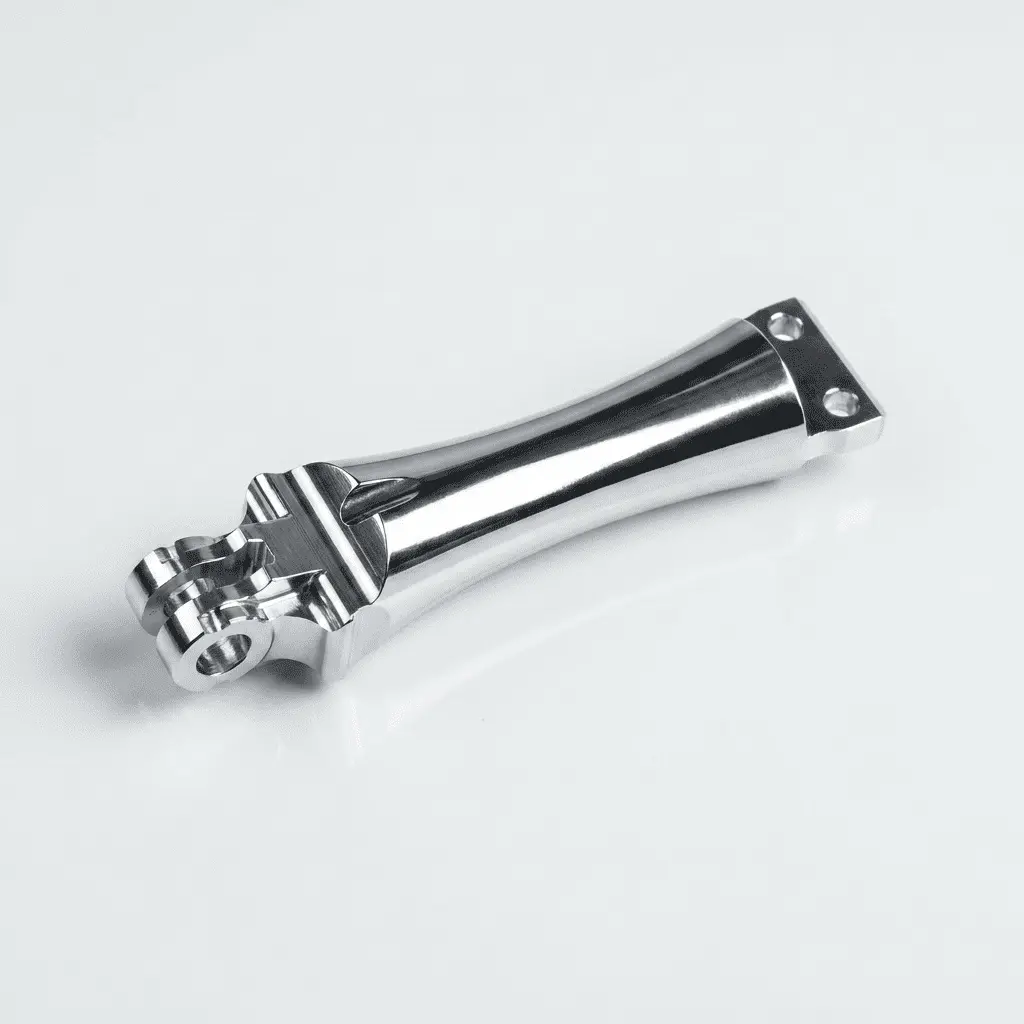
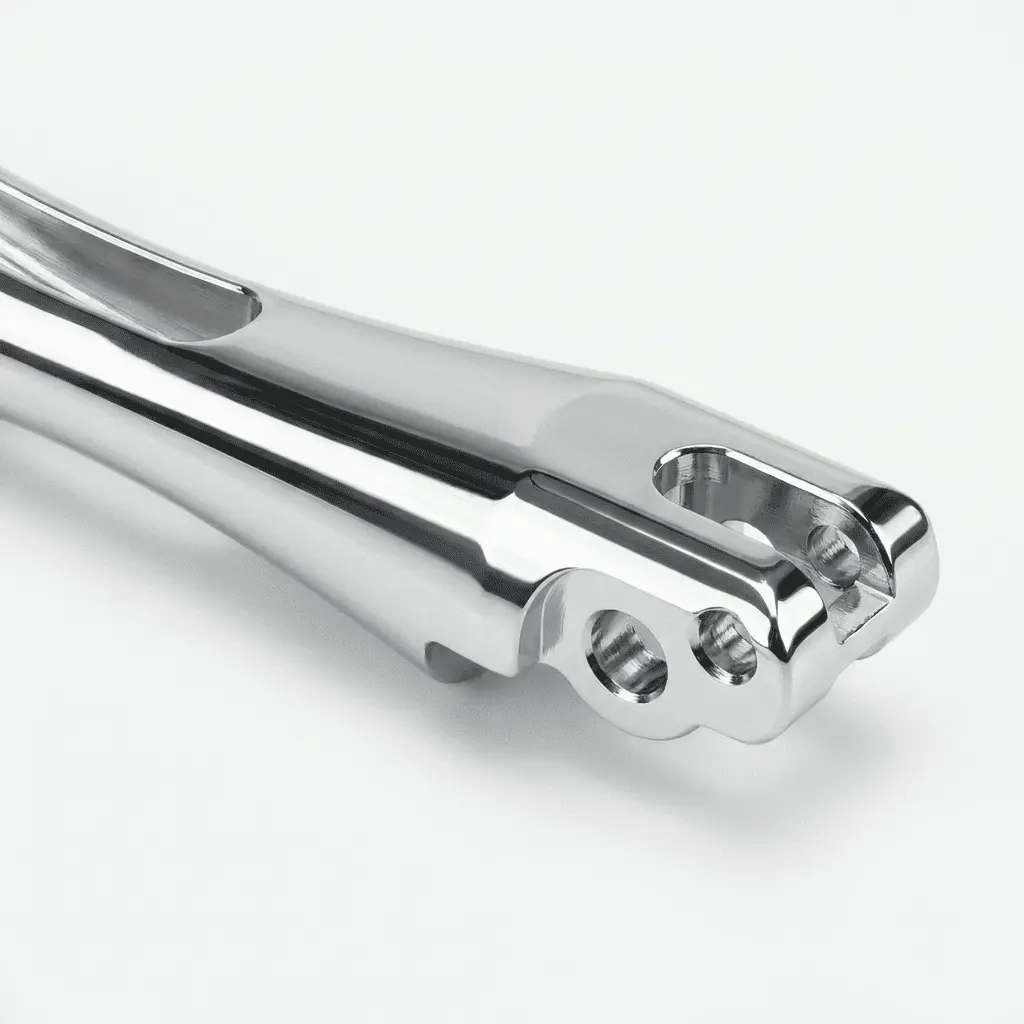
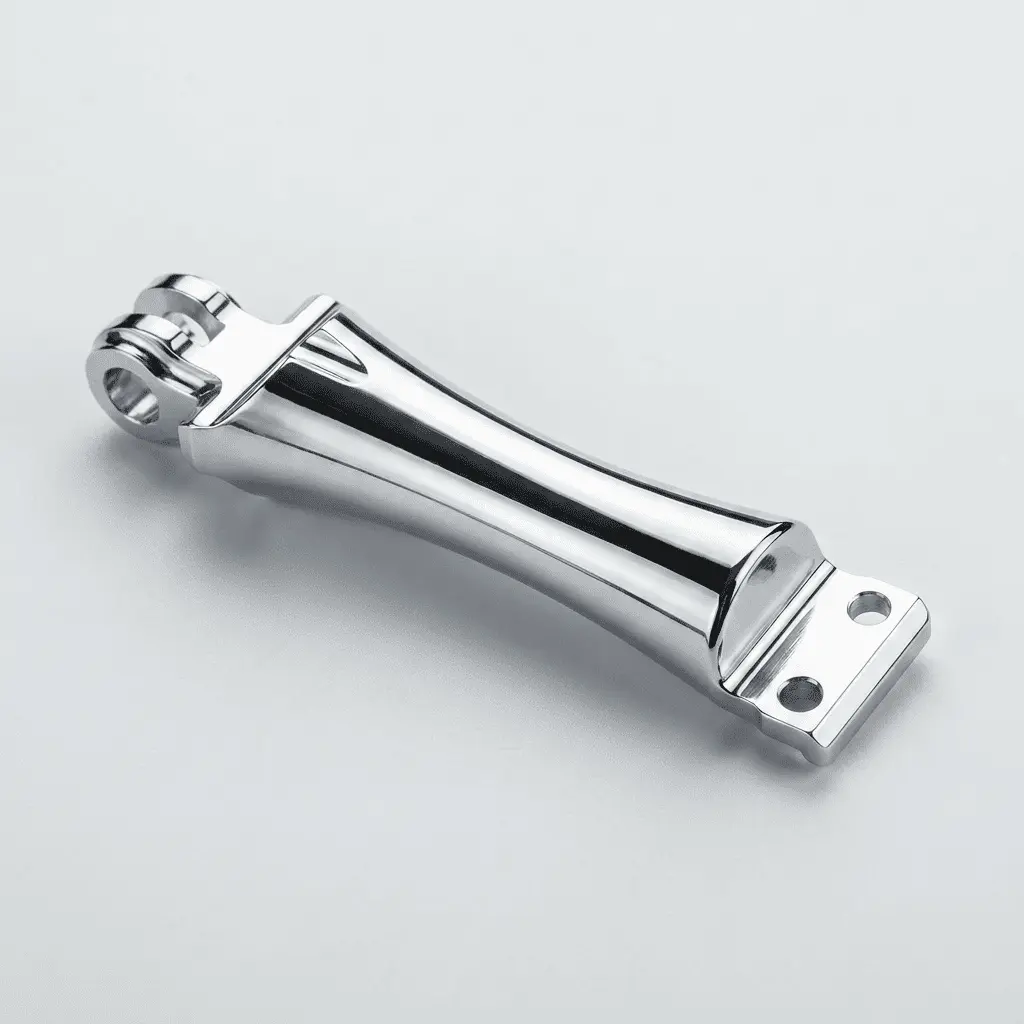
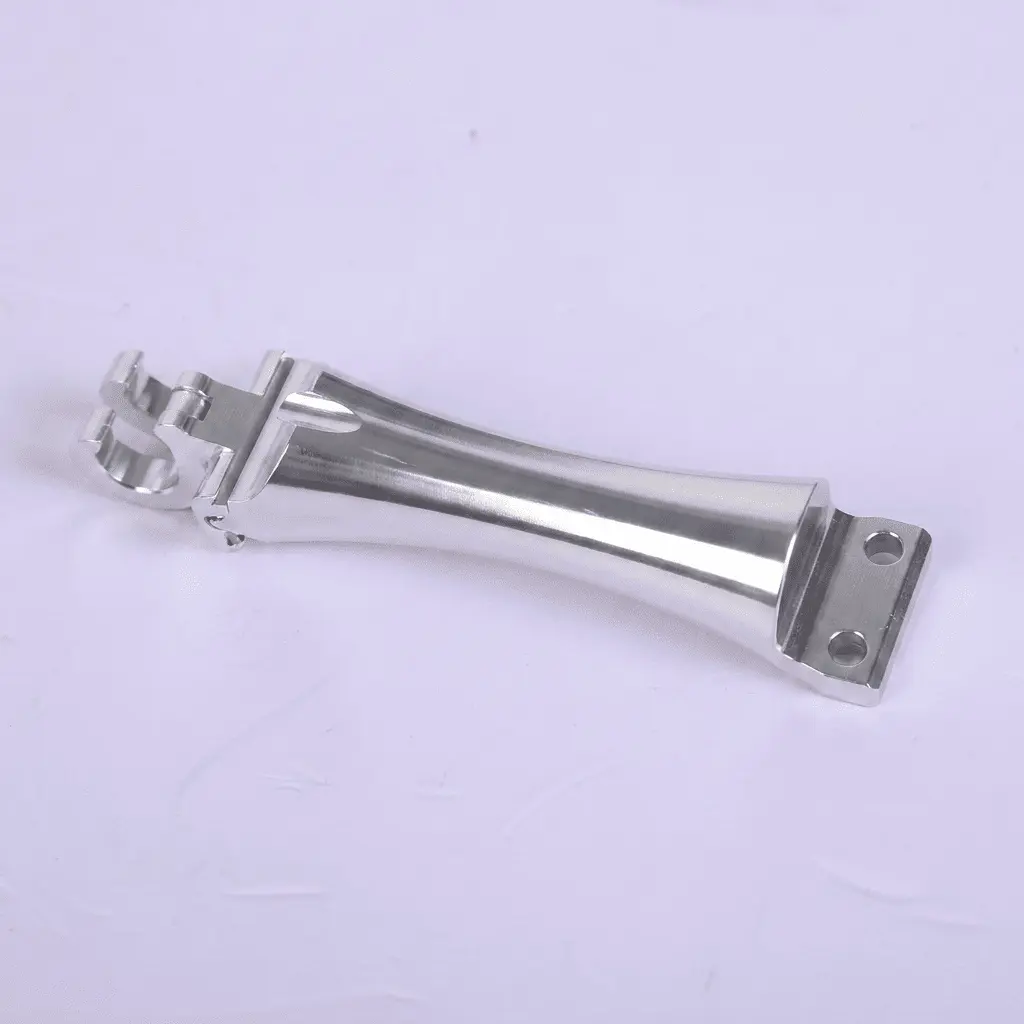
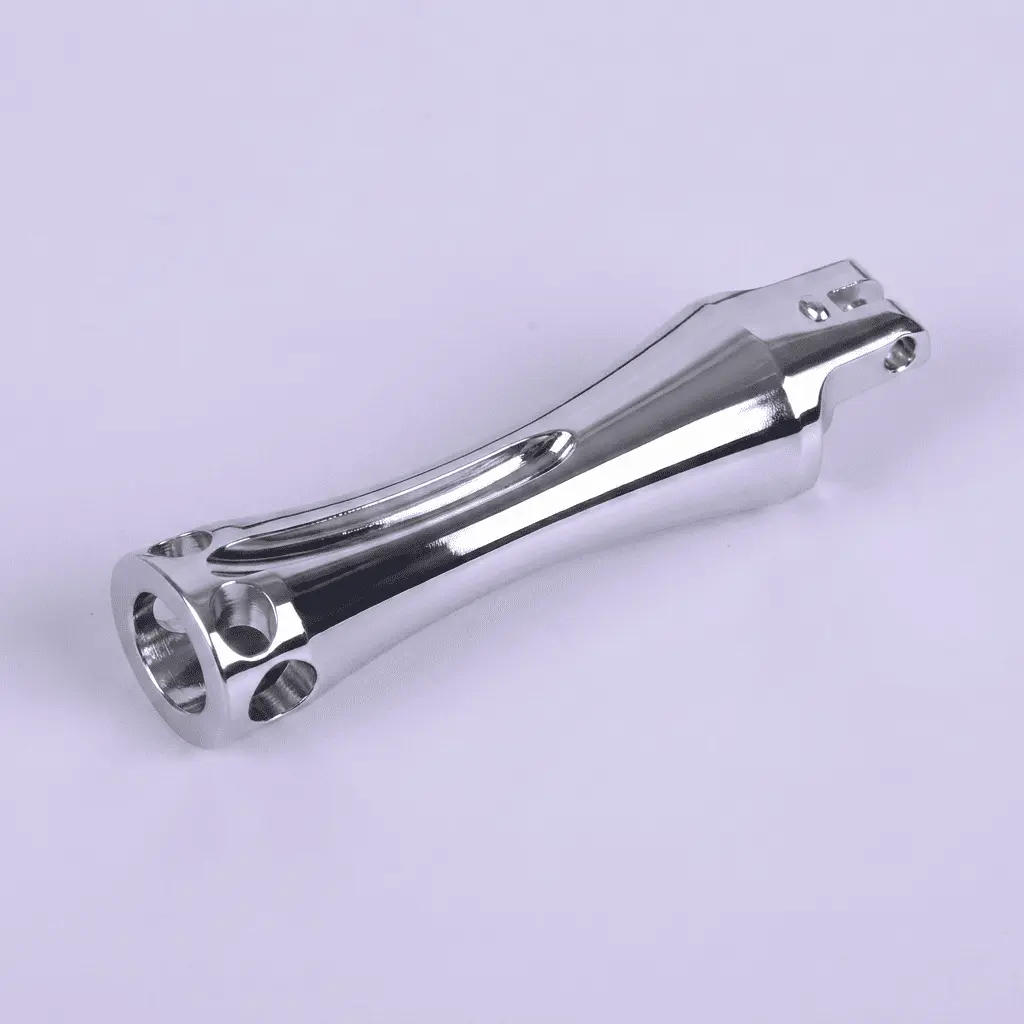
Shenzhen Sunmy Hardware Co., Ltd. manufactures custom CNC machined robot finger joint links for customer-designed robotic hands and articulated mechanisms. The illustrated variants combine contoured metal bodies, forked ends, transverse bores and different mounting interfaces. Each configuration is manufactured to the customer's assembly design, with the required application and mating parts defined before production.
This is a fully customizable OEM/ODM component, not a fixed-size catalog item. Overall length, body profile, relief features, fork opening, hole pattern, threads, material and finish can all be manufactured to customer requirements. We work from 2D drawings, 3D CAD models or physical samples, agreeing material, critical fits and acceptance criteria before production.
Manufacturing & Process Insights
- CNC Machining & Datum Planning: Milling, drilling, boring and tapping are planned around the approved drawing. Multi-axis or 5-axis machining is selected where geometry and access require it. Workholding and machining sequences are planned to control hole-to-hole and hole-to-face relationships.
- Contoured Profiles & Relief Features: Curved surfaces, open recesses and fork profiles are machined to the customer's CAD model. DFM review addresses cutter access, internal radii, section thickness and workholding. Proposed geometry changes require customer approval before manufacture.
- Pivot Bores & Mounting Interfaces: Bore diameter, fork gap, mounting-hole spacing and datum relationships are controlled to the drawing. Reaming or boring is selected for the specified fit, with pin clearance, bearing seats and geometric tolerances defined individually.
- Deburring & Surface Finishing: Hole edges, fork openings and machined recesses are reviewed for burr removal. Polishing and other material-compatible finishes are specified separately from dimensional requirements. Functional bores and mounting faces are protected or rechecked after finishing.
Technical Specifications
| Parameter / Feature | Specification / Capability | Engineering Notes |
|---|---|---|
| Product Name | Custom CNC Machined Robot Finger Joint Link | Fully custom to customer drawings or samples |
| Core Function | Structural link for articulated robot mechanisms | Application and load case per customer design |
| Manufacturing Process | CNC milling, drilling, boring and tapping | Multi‑axis / 5‑axis machining as geometry requires |
| Material Options | Aluminum 6061‑T6 / 7075‑T6; 304 / 316L stainless; Ti‑6Al‑4V | Material grade and condition specified for each order |
| Critical Feature Tolerance | Bore fits, hole positions and datum controls to drawing | Feature‑specific requirements confirmed before production |
| General Tolerance | As stated on the approved engineering drawing | Specify the standard, class and separate GD&T controls |
| Surface Finish | Bright polished appearance shown; custom finishes available | Ra, coating and visual acceptance specified separately |
| Mounting Interface | Two‑hole flange or alternative end configuration | Hole count, pitch, threads and orientation are customizable |
| Articulation End | Fork / clevis with transverse bores | Fork gap, lug thickness and mating‑pin fit to drawing |
| Quality & Inspection | Dimensional and surface checks to the agreed plan | CMM / optical checks and report scope specified per project |
| Customization Scope | Full OEM/ODM; drawings, CAD models or samples | Custom geometry, interfaces, material and finish |
| File Formats Accepted | STEP (.stp), IGES (.igs), SolidWorks, DXF, DWG, PDF | Include critical fits, datums and surface requirements |
| Production Volumes | Prototype, pilot and repeat‑volume orders | Order quantities and delivery schedule confirmed in quotation |
Key Features & Engineering Advantages
- Full Geometry Customization: Specify link length, profile, fork opening, mounting pattern and relief features around your mechanism. The photographed variants illustrate configuration choices; your design is not restricted to these proportions or interfaces.
- Fit-Focused Manufacturing: We coordinate bore sizes, lug spacing and mounting datums with the specified mating parts. Required clearance and alignment are established through the approved drawing and sample review.
- Material & Finish Options: Polishing, aluminum anodizing, electroless nickel and PVD can be evaluated for the selected alloy and service requirements. Cosmetic surfaces and functional interfaces receive separate acceptance criteria.
- Direct Engineering Support: Sunmy reviews CAD files or samples for machining access, workholding and inspection needs. Agreed drawings and sample feedback guide the transition from prototypes to repeat orders, with changes documented before production.
Technical FAQ for Global Buyers
Q1
Can the link be fully customized to our design?
Yes. Dimensions, contours, fork openings, holes, threads, materials and finishes can all be customized. Send 2D drawings with a 3D model, or a physical sample. For samples, we agree the reconstructed geometry and critical requirements before manufacture.
Q2
What CAD file formats do you accept for engineering evaluation?
We accept STEP (.stp), IGES (.igs), SolidWorks, DXF, DWG, and PDF formats. Please include critical fits, datums, and specific surface finish requirements in your documentation.
Q3
How are critical tolerances and assembly fits confirmed?
Provide the required bore fits, datums, hole positions and surface requirements. We review each critical feature and confirm the manufacturing and inspection plan in the quotation. Sample dimensions and fit checks are assessed against the approved requirements.
Q4
What material and surface finishing choices can be provided?
We work with Aluminum 6061-T6/7075-T6, 304/316L Stainless Steel, and Titanium Ti-6Al-4V. Available surface treatments include mechanical bright polishing, anodizing, electroless nickel plating, and PVD coatings tailored to functional requirements.
Q5
Can you support prototypes as well as repeat production?
Yes. We support prototype, pilot and repeat-volume orders. Quantities and delivery dates are confirmed after reviewing geometry, material, finishing and inspection scope. Include first-order quantity, expected repeat demand and the required delivery date with your enquiry.
Q6
What quality documentation can be included with the shipment?
The agreed order can include material documents, dimensional inspection results, surface-finish measurements and a certificate of conformity. Methods, sampling and report coverage are defined before production. Send your drawings, material specification, quantities and documentation requirements for a project-specific quotation.
Other Products
Custom Modular Plastic Enclosures...
Custom Die Cast Aluminum Finned H...
Custom Injection Molded Electroni...
Custom Precision Sheet Metal Equi...
Get a Fast, Technical Quote & Free DFM Review
Don't let tolerance stack-up delay your product launch. Submit your project details, and our engineering team will evaluate your design for manufacturability before the first cut.









